MIRACOSTA COLLEGE · NASA SPACE GRANT PROJECT
PLATO: S.H.E.L.L.
Remote-controlled soil-moisture rover.
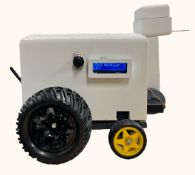
I worked on CAD, electronics, Arduino C++ programming, testing, and parts selection for a four-person NASA Space Grant team at MiraCosta College. We built a remote-controlled rover that measures soil moisture.
What I worked on
CAD, electronics, and code
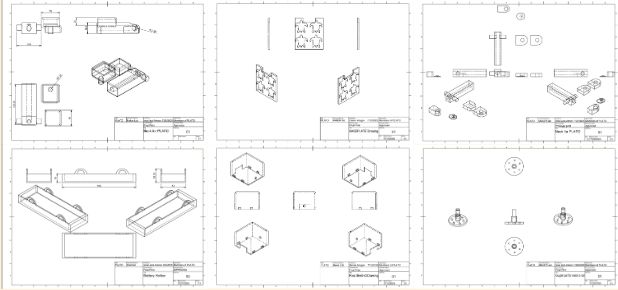
My role covered most of the build: mechanical CAD, electronics, Arduino C++ code, component selection, and testing. Everyone on the team shared responsibilities, and I helped get the mechanical and electronic parts working together.
Hardware
An Arduino Uno R4 WiFi processes joystick and switch inputs in the controller; an Arduino Mega handles the rover's motors, servos, and sensor interfaces. NRF24L01 radios connect the two. A capacitive soil-moisture sensor feeds an LCD mounted on the rover.
Changes during the build
We originally wanted soil-moisture readings on the controller. After running into radio communication issues and limited time, we mounted the LCD on the rover and added a controller switch to freeze the reading. We also reused parts and adjusted the mechanical fit to stay within budget.
Outcome
We demonstrated the rover outdoors and produced mechanical drawings, circuit documentation, and a final presentation. The project gave me hands-on experience debugging a robot across CAD, wiring, and firmware.
Team: Darien Aragon, Ismael Anderson, Nico Leon, and Patricia Lau. Faculty advisor: Juan Castillejos.